XRHQ
DeploymentPilot

Daiichi Sankyo Pilots Apple Vision Pro Control of a Collaborative Robot

Daiichi Sankyo's DX Planning Department tests Vision Pro teleoperation of a dual-arm cobot, built by HoloLab.

Japan
Pharmaceuticals
Added on

Worked on this project?

Get credited on this page

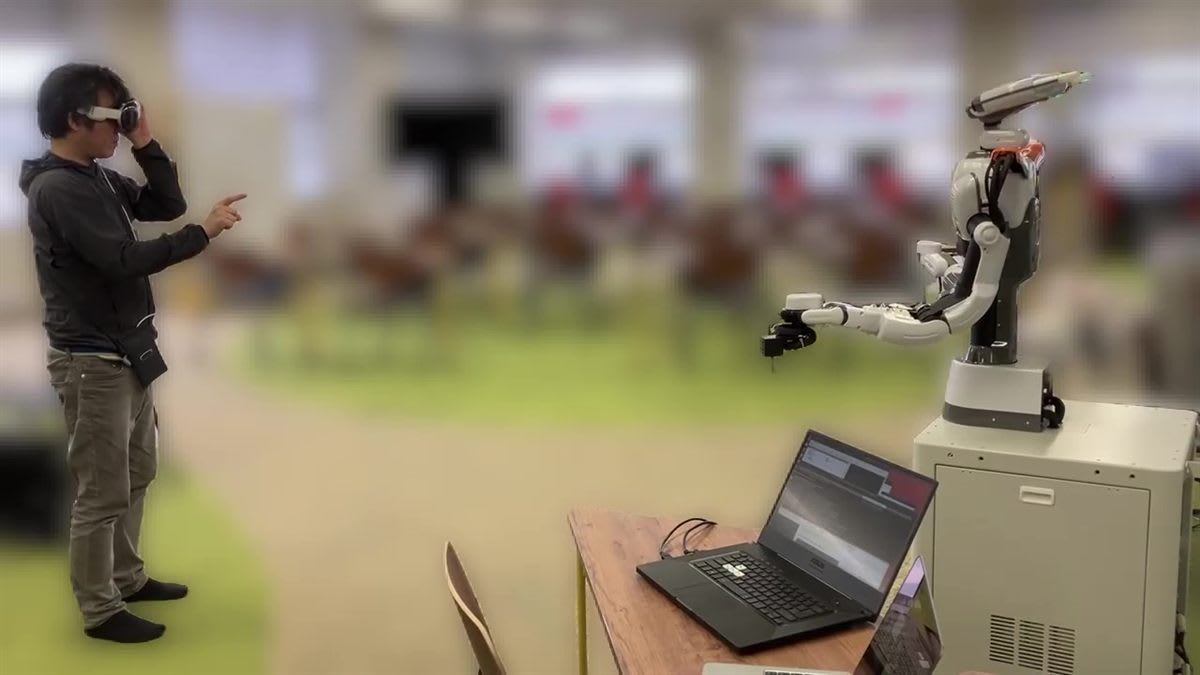
A person wearing an Apple Vision Pro headset gestures with one hand while a white dual-arm collaborative robot on a wheeled cabinet moves its arm; a laptop running the control software sits on a table in front.
An operator wearing Apple Vision Pro remotely steers a dual-arm collaborative robot in HoloLab's teleoperation demo app developed for Daiichi Sankyo's DX Planning Department.

Daiichi Sankyo's DX Planning Department has piloted a demo application that lets an operator steer a dual-arm collaborative robot with Apple Vision Pro. HoloLab developed the app as part of work on digital transformation of pharmaceutical tasks in the digital factory domain, using collaborative robots to connect the physical and the digital.

How it works

The operator grabs and moves the hands of a virtual dual-arm robot in a simulator, and the real robot follows. The physical machine is Kawada Robotics' NEXTAGE Fillie OPEN dual-arm collaborative robot. HoloLab lists the work under manufacturing, robot teleoperation verification and ROS, and built it in Unity.

Status

HoloLab describes the application as a demo, so the work is treated as a pilot rather than a production rollout. HoloLab's CEO presented the Daiichi Sankyo teleoperation demo as a real case at an XR Kaigi Nagoya 2026 session on physical AI, as reported by Mogura VR.

Project Summary

This information is available to registered members of XRHQ. Sign up for free below.

Experience

Available to XRHQ members

Hardware

Available to XRHQ members

Software

Available to XRHQ members

Partners & Service Providers

Available to XRHQ members

Sources

Available to XRHQ members

Know more about this project? Help us fill in any missing details.

Edit this project →

Worked on this project?

Get credited on this page

This write-up is free to reuse with credit — CC BY 4.0.